I’m a researcher passionate about exploring the intersection of Mathematical Engineering, Robotics, Control Systems, and Autonomous Technologies, with hands-on experience in industrial automation beyond theoretical research. I enjoy challenging engineering problems, particularly those involving sensing, computer vision, and automation.
Here you can find an overview of the main projects I have worked on throughout my career, beginning with my Master’s degree. Each project is presented with a brief description, and where available, you can use the button next to the project image to explore further information, such as a related paper, publication, or more detailed description of the work.

Path Planning for AUV Docking
For this project, I designed a path-planning framework for an Autonomous Underwater Vehicle (AUV) to generate feasible trajectories. Given the initial state of this non-holonomic system, the objective is to generate a feasible sequence of control inputs that drives the AUV toward a docking station while satisfying specific terminal conditions, including a desired final orientation and zero velocity. The framework was subsequently tested in a confined environment using a real AUV.

Lane Detection Algorithm
In this project, we compared two different Bayesian filters for detecting highway lanes in nighttime video footage. Each frame was processed using different image-enhancement techniques to improve lane visibility. We then applied both a Particle Filter and a Kalman Filter to detect and track the lanes and compare their performance.

Autonomous Pac-Man Agent
This paper presents our proposed Multi-Agent Systems solution for a “Pac-Man: Capture the Flag” simulation, serving as a fundamental model for addressing more complex tasks using multi-agent systems. Our team achieved 14th place out of 30 participating teams.
Autonomous Battle Snake Agent
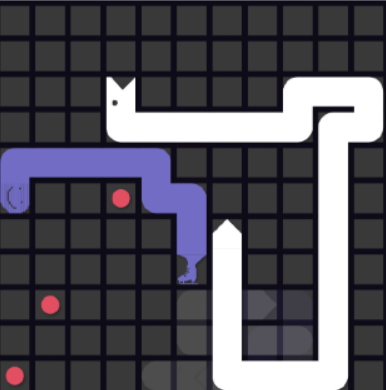
This research evaluated the performance of our algorithm in a fast-paced “BattleSnake” game environment, where prioritizing safe movement across the map was crucial. We developed a novel approach to navigating the environment while keeping the computational requirements low enough for real-time execution on the server. Our team achieved 2nd place out of 30 participating groups.
Design of 2 Seats E-Aircraft
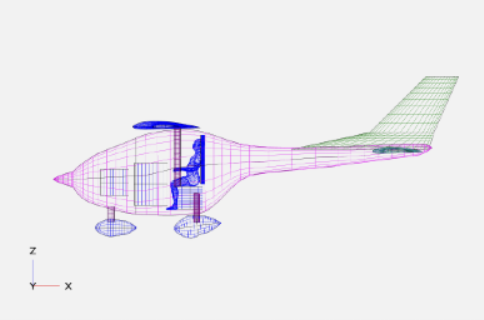
This project focused on the design of a two-seat electric aircraft, including the definition and analysis of its main characteristics. The work covered the complete design process, starting with the initial constraints and weight analysis, followed by aerodynamic analysis and the study of aircraft stability and control.
Real-Time Blob Detector
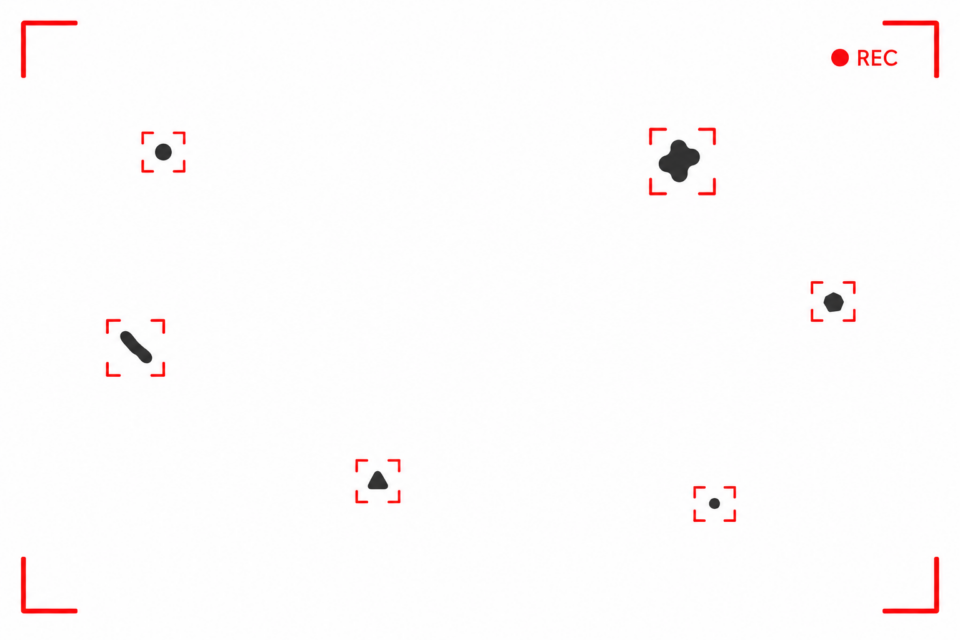
This project consists of software that automatically detects the presence of water bubbles within a camera frame. It uses Python and OpenCV for detection, a Particle Filter for tracking, and a statistical method to assign a score to each detection. This approach improves detection precision while reducing false positives.

Real-time AI Lego Game
This small project aims to create a fun LEGO-sorting game using the YOLOv8 deep-learning model. The system first generates a sequence of LEGO brick colors and then detects the bricks in real time, drawing a frame around each detected brick. A red frame indicates that a brick is in the wrong position, while a green frame indicates that it has been correctly placed. A timer was also implemented to measure how quickly the user can sort the bricks.

Industrial Prototypes and Software
I have also designed, developed, and produced sensors for an industrial production line by 3D-printing individual components and integrating microcontrollers. The final prototypes were successfully deployed in an industrial environment to monitor and collect critical process information. In addition, I developed software capable of determining whether a surface is smooth and detecting and locating imperfections. Finally, I designed and prototyped a tool integrating microcontrollers and industrial sensors to assist operators in their daily activities. For this project, I personally assembled all components and designed and built the associated electrical circuits.